Drone ESC Guide for Reliable Power, Control, and Better Flight Performance
A drone ESC is one of the most important electronic components in a multirotor because it controls how electrical power from the battery reaches each motor. The flight controller continuously sends motor commands to the electronic speed controller, and the ESC responds by driving the brushless motor faster or slower. That rapid control is what allows a quadcopter to climb, descend, roll, pitch, yaw, hover, and react to disturbances during flight. Modern flight systems can use digital communication protocols such as DShot, while advanced ESCs can also return telemetry such as motor RPM, temperature, voltage, and current depending on the hardware and firmware.
Choosing an ESC is therefore not simply a matter of finding a board with enough motor outputs.
Voltage compatibility, current capability, firmware, communication protocol, physical size, cooling, motor choice, battery type, and flight style all matter.
An incorrectly matched ESC can lead to overheating, motor desynchronisation, unstable performance, electrical failure, or damage to other components.
Understanding how ESCs work makes it much easier to build and maintain a reliable drone.
What Is a Drone ESC?
ESC stands for Electronic Speed Controller.
In a brushless drone, the ESC sits between the battery and motor while also receiving commands from the flight controller.
The flight controller determines how much thrust each motor should produce.
The ESC translates those commands into carefully timed electrical switching across the three motor phases.
PX4 documentation describes this relationship directly: brushless drone motors are driven through ESCs, which receive commands from the flight controller and control the electrical power delivered to the motors.
A typical multirotor system therefore contains:
• Battery
• Power distribution path
• Flight controller
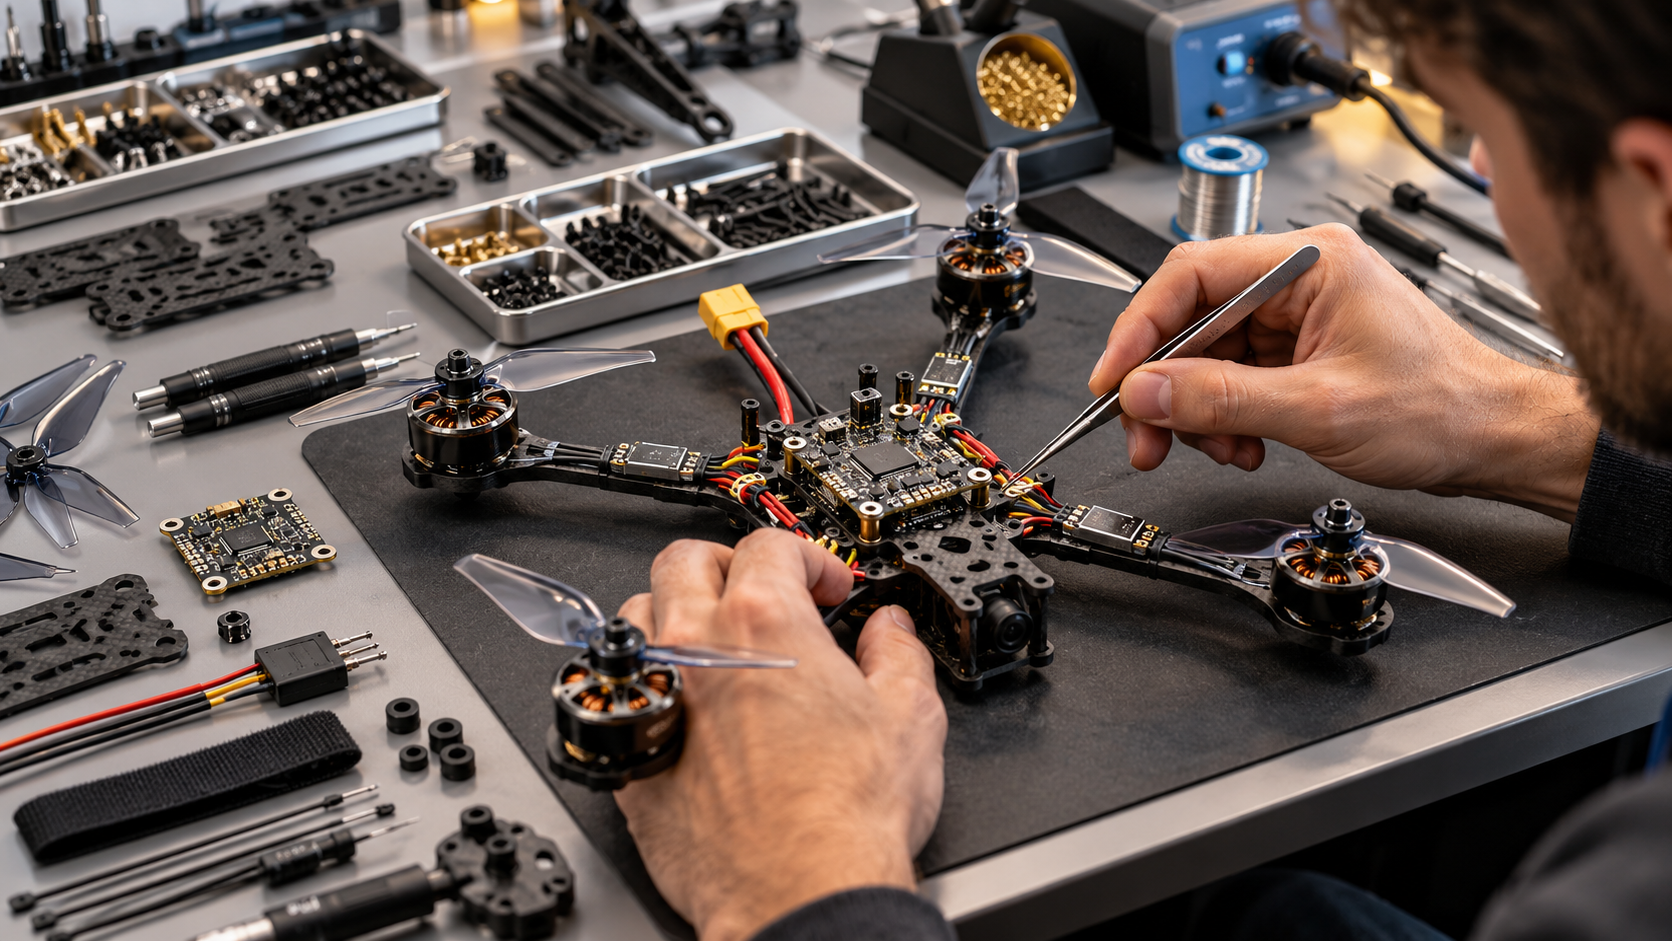
• ESC or 4 in 1 ESC
• Brushless motors
• Propellers
The flight controller manages vehicle behaviour.
The ESC manages motor power.
Why Brushless Motors Need an ESC
A brushless motor cannot simply be connected directly to the battery and expected to operate normally.
It contains multiple windings that must be energised in the correct sequence.
The ESC switches current through these windings thousands of times per second.
This creates the rotating magnetic field needed to turn the motor.
The ESC also changes the switching sequence and power according to the throttle commands sent by the flight controller.
How a Drone ESC Works
A modern ESC receives battery voltage through its power connections.
It also receives a control signal from the flight controller.
Inside the ESC, electronic switching devices rapidly control current flowing to the motor.
The process happens fast enough that pilots experience smooth and almost immediate changes in motor speed.
When the flight controller detects that the drone is tilting, it can command some motors to speed up and others to slow down.
The ESCs execute those commands.
This continuous adjustment makes stable multirotor flight possible.
Drone ESC Communication With the Flight Controller
Different communication protocols can be used between the flight controller and ESC.
PX4 currently supports protocols including PWM, OneShot, DShot, DroneCAN, and several other arrangements depending on the hardware.
FPV drones commonly use DShot because it provides digital communication and several practical advantages.
7 Powerful Tips for Choosing the Right Drone ESC
An ESC should be selected as part of the complete power system rather than independently.
1. Match the Drone ESC Voltage to the Battery
The first specification to check is supported battery voltage.
Drone batteries are commonly described by their cell count.
For example, lithium polymer packs may be described as:
• 2S
• 3S
• 4S
• 6S
The letter S refers to cells connected in series.
Each additional cell increases the total battery voltage.
The ESC must be rated for the battery you intend to use.
Connecting a battery above the ESC’s supported voltage can damage the controller.
Do not assume that two physically similar ESCs support the same battery.
Read the manufacturer specification.
Consider the Entire Power System
Battery voltage also needs to match:
• Motors
• Propellers
• ESC
• Capacitors
• Other voltage sensitive electronics
A 6S battery may provide excellent performance when the system is designed for it, but installing one in a system intended only for lower voltage operation can cause immediate failure.
2. Choose a Suitable Current Rating
ESCs are commonly sold with current ratings such as:
• 20A
• 30A
• 40A
• 45A
• 55A
• 60A
• 80A
The correct rating depends on how much current the motor and propeller combination may draw.
Motor current can change dramatically with propeller size, pitch, battery voltage, and throttle.
A larger propeller can require significantly more current than a smaller one even when the same motor is used.
Drone ESC Current Ratings Need Headroom
Avoid designing a power system where the expected maximum motor current exactly matches the ESC’s advertised limit.
Some electrical and thermal margin is useful.
Actual conditions can vary because of:
• Aggressive throttle
• Propeller differences
• Motor efficiency
• Battery voltage
• High ambient temperature
• Cooling airflow
• Vehicle weight
• Motor loading
Manufacturer motor test data can help when selecting an ESC.
Bench testing should be performed carefully with suitable equipment.
3. Check Motor Compatibility
The motor and ESC must work together as a system.
Important motor characteristics include:
• KV rating
• Maximum current
• Recommended battery voltage
• Recommended propeller
• Motor size
• Pole count
KV represents approximate unloaded motor speed per volt and should not be confused with power.
A high KV motor is not automatically more powerful.
Its suitability depends on the rest of the system.
Motor and Propeller Combination Matters
Suppose the same motor is tested with two different propellers.
The larger or more aggressive propeller may demand substantially more electrical current.
This means an ESC that is adequate for one propeller may run too close to its limits with another.
Always evaluate the motor, propeller, battery, and ESC together.
4. Use the Right ESC Protocol
Older systems commonly relied on analogue control protocols.
Modern multirotors often use digital DShot.
Betaflight describes DShot as a popular standard for communication between flight controllers and ESCs in quadcopters. It uses digital signalling and includes error checking through a checksum.
PX4 also recommends DShot for vehicles that benefit from reduced latency and notes advantages including robust digital communication, telemetry support on compatible hardware, and no requirement for traditional ESC calibration.
Common versions include:
• DShot150
• DShot300
• DShot600
The number corresponds to signalling speed.
Higher numbers are not automatically better for every aircraft.
The flight controller and ESC both need to support the selected protocol.
5. Understand Drone ESC Firmware
Firmware controls how the ESC behaves.
Different firmware families support different features and hardware.
Betaflight currently documents modern ESC firmware and recommends DShot with RPM filtering where compatible. It also explains that modern bidirectional DShot can return motor telemetry to the flight controller.
Examples encountered in drone systems include:
• AM32
• Bluejay
• BLHeli_S
• Other manufacturer specific firmware
BLHeli_S remains available as open source sensorless brushless ESC firmware through its public repository.
Firmware support matters because it can influence:
• DShot compatibility
• Motor timing
• Bidirectional telemetry
• Startup behaviour
• Motor direction
• PWM frequency
• Configuration options
Never flash firmware simply because another pilot recommends it.
Confirm that the firmware and target are compatible with the exact ESC hardware.
6. Provide Adequate Cooling
ESCs convert large amounts of electrical power while switching motor phases rapidly.
This produces heat.
Poor cooling can reduce performance and increase the chance of failure.
Cooling is influenced by:
• Airflow
• ESC placement
• Frame design
• Current draw
• Ambient temperature
• Battery voltage
• Motor loading
• ESC efficiency
A racing drone with strong airflow may cool its electronics differently from a heavily enclosed cinematic platform.
Avoid completely covering heat producing components unless the design specifically allows it.
7. Choose Between Individual and 4 in 1 ESCs
Multirotors can use separate ESCs for each motor or a single board containing four ESC channels.
A 4 in 1 ESC is extremely common in compact quadcopters.
It places four motor controllers on one circuit board.
Advantages can include:
• Cleaner wiring
• Compact installation
• Lower component count
• Easy flight stack assembly
• Central power connection
Individual ESCs can offer their own benefits.
For example, damage to one separate ESC may allow only that component to be replaced.
The best configuration depends on the drone design.
What Is a 4 in 1 Drone ESC?
A 4 in 1 ESC combines four electronic speed controllers onto one board.
Each channel controls one motor.
The board normally sits close to the flight controller in a compact stack.
Connections usually include:
• Battery positive
• Battery negative
• Four motor outputs
• Control signals
• Ground
• Telemetry where supported
• Current sensing on some boards
The exact connector layout varies by manufacturer.
Never assume that two stack connectors use the same pin order.
Incorrectly connecting a flight controller and ESC through a mismatched cable can damage electronics.
Drone ESC and DShot Explained
DShot means Digital Shot.
Unlike traditional analogue throttle protocols, DShot sends digitally encoded commands from the flight controller to the ESC.
PX4 highlights several advantages:
• Reduced latency compared with older protocols
• Checksum based robustness
• No traditional ESC calibration
• Telemetry support on compatible ESCs
• Commands for functions such as motor direction changes
These capabilities make DShot attractive for modern multirotors.
DShot150, DShot300, and DShot600
The different DShot versions use different signalling rates.
PX4 recommends selecting a rate supported by the ESC and notes that lower rates may be more robust for some installations, particularly systems involving longer signal leads.
For a typical compact FPV drone, DShot300 or DShot600 may be used depending on hardware and firmware.
Use the recommendations for your flight controller and ESC rather than selecting the highest number automatically.
Bidirectional DShot and RPM Telemetry
Bidirectional DShot allows information to travel back from the ESC toward the flight controller through the motor signal connection.
Betaflight uses this capability for RPM telemetry and filtering.
Modern Betaflight documentation recommends DShot together with RPM filtering when compatible hardware and firmware are available.
RPM data can help the flight controller identify motor related vibration frequencies.
This allows filtering to respond more precisely to actual motor behaviour.
Extended ESC Telemetry
Some modern systems can provide additional information such as:
• RPM
• Temperature
• Voltage
• Current
PX4 documents DShot ESC telemetry and extended bidirectional DShot telemetry for compatible hardware.
Availability depends on the ESC design, firmware, and flight controller.
Does a Drone ESC Need Calibration?
The answer depends on the protocol.
Traditional PWM and some older protocols may require calibration so the ESC understands minimum and maximum throttle values.
PX4 states that its ESC calibration procedure applies to PWM and OneShot ESCs, while DShot and CAN based ESCs do not require this form of calibration.
If using DShot, do not perform unnecessary traditional throttle calibration.
Follow the instructions for the flight firmware and ESC combination.
Drone ESC Telemetry
Telemetry allows the flight controller or pilot to monitor aspects of ESC performance.
Depending on the system, useful information can include:
• Motor RPM
• ESC temperature
• Voltage
• Current
• Energy consumption
Telemetry can help identify problems before they become obvious.
For example, one motor running at noticeably different RPM from the others under similar conditions may indicate a mechanical or electrical issue.
Temperature telemetry may also help detect excessive load.
How to Wire a Drone ESC Correctly
Wiring errors can destroy components instantly.
Before soldering, identify every connection.
Battery Connections
The battery connects through heavy power wires.
Polarity is critical.
Reversing battery polarity can destroy an ESC and other electronics.
Double check positive and negative connections before applying power.
Motor Connections
A brushless motor normally uses three phase wires.
Swapping the appropriate phase relationship changes motor direction on many conventional systems, although modern digital ESC configurations may also support changing direction through software.
PX4 notes that DShot can support commands to reverse motor direction on compatible systems.
Flight Controller Connections
The flight controller provides motor control signals.
A 4 in 1 ESC may connect through a cable carrying several signals and power related connections.
Check both pin diagrams carefully.
Matching connector shapes do not guarantee matching pinouts.
Why Capacitors Are Used With Drone ESCs
Many drone builds include a capacitor close to the battery input.
Rapid current changes can produce electrical noise and voltage spikes.
An appropriately selected capacitor can help reduce disturbances on the power system.
The capacitor must have suitable:
• Voltage rating
• Capacitance
• Temperature rating
• Polarity where applicable
Electrolytic capacitors are polarity sensitive.
Installing one backwards can cause failure.
Follow the ESC manufacturer’s recommendation.
Common Drone ESC Problems
ESC problems can appear in several ways.
Motor Does Not Spin
Possible causes include:
• Damaged motor
• Broken motor wire
• Poor solder joint
• Incorrect motor mapping
• ESC failure
• Firmware configuration problem
• Signal connection problem
Swap testing should be performed carefully to determine whether the fault follows the motor or remains with the ESC channel.
Motor Stutters
Stuttering can indicate that the ESC is struggling to commutate the motor properly.
Possible causes can include:
• Damaged motor winding
• Poor phase connection
• Incorrect firmware settings
• Mechanical obstruction
• ESC damage
• Excessive load
Do not repeatedly run a stuttering motor at high throttle.
ESC Overheats
Excess heat can result from:
• Excessive current
• Poor airflow
• Oversized propellers
• Motor damage
• Aggressive settings
• Electrical faults
• Operating near the ESC limit
An ESC that becomes abnormally hot should be investigated before further flight.
Drone Flips During Takeoff
An immediate flip after arming can result from several setup errors.
Possible causes include:
• Incorrect motor order
• Wrong motor direction
• Incorrect propeller orientation
• Flight controller orientation error
The ESC itself may be working correctly.
Always perform motor checks without propellers installed.
Drone ESC Safety During Setup
Propellers can cause serious injury.
Remove them whenever configuring or testing motor direction on the bench.
PX4 specifically warns users to remove propellers before changing ESC configuration parameters.
This is one of the most important habits in drone building.
Before connecting a battery after major electrical work, also inspect:
• Power polarity
• Solder bridges
• Loose wires
• Damaged insulation
• Connector orientation
• ESC mounting
• Motor screws
A current limiting smoke stopper can provide additional protection during initial power testing on compatible hobby builds.
How to Choose a Drone ESC for FPV
FPV drones often place high demands on ESCs because pilots make rapid throttle changes.
When choosing an FPV ESC, consider:
• Battery cell support
• Continuous current rating
• Burst capability
• DShot support
• Bidirectional DShot compatibility
• Firmware
• Board size
• Mounting pattern
• Connector layout
• Cooling
• Telemetry
• Reputation for reliability
The highest current rating is not always necessary.
A correctly matched ESC can reduce cost and weight while still providing adequate performance.
Drone ESC for Cinematic and Long Range Builds
Cinematic and long range drones may prioritise different characteristics.
Instead of maximum burst performance, the builder may care more about:
• Efficiency
• Smooth motor control
• Reliability
• Low electrical noise
• Telemetry
• Cooling
• Lightweight design
• Stable firmware
Long duration flights can expose electronics to sustained current for extended periods.
Thermal performance becomes particularly important.
How to Protect a Drone ESC From Failure
No electronic component is guaranteed to last forever, but good build practices can reduce unnecessary failures.
Use the Correct Propeller
Do not install a much larger propeller without checking motor current.
Keep Soldering Clean
Poor solder joints increase electrical resistance and may fail under vibration.
Prevent Short Circuits
Inspect for loose wire strands and solder bridges.
Secure the ESC
Electronic boards should not move freely inside the frame.
Keep Water Away
Standard hobby ESCs should not automatically be considered waterproof.
Moisture can cause corrosion and electrical shorts.
Monitor Temperature
Unexpected heat can indicate a developing problem.
Frequently Asked Questions
What does a drone ESC do?
A drone ESC receives commands from the flight controller and controls electrical power delivered to a brushless motor, allowing the aircraft to continuously adjust motor speed for stable flight.
What current rating should a drone ESC have?
The rating should exceed the realistic current demand of the selected motor, propeller, and battery combination with appropriate operating margin. Manufacturer motor test data can help estimate requirements.
What is a 4 in 1 drone ESC?
A 4 in 1 ESC combines four individual motor controllers on one circuit board, allowing one compact unit to operate all four motors on a typical quadcopter.
Does a DShot drone ESC need calibration?
Traditional throttle calibration is not required for DShot. PX4 states that calibration is relevant to PWM and OneShot ESCs, while DShot and CAN ESCs do not require that process.
What is bidirectional DShot?
Bidirectional DShot allows compatible ESCs to return motor information such as RPM to the flight controller over the signal connection, enabling features such as RPM based filtering.
Why does my drone ESC get hot?
An ESC may overheat because of excessive motor current, poor cooling, oversized propellers, motor problems, electrical faults, or operation near its limits. Stop testing and investigate abnormal temperatures before flying.
Conclusion
A drone ESC is a critical link between the flight controller, battery, and brushless motors, so correct selection has a direct effect on performance and reliability. Voltage compatibility, current capacity, motor and propeller choice, firmware, DShot support, cooling, telemetry, and wiring should all be considered as part of one complete power system. By selecting compatible components, maintaining clean electrical connections, and testing safely without propellers, builders can create a drone power system that responds smoothly and operates with greater reliability.